We are creating Infrastructure-Based Digital Twins That Work
How We Work: What to Expect
Our work is guided by a practical goal: help engineering teams observe, coordinate, and evaluate road scenarios with infrastructure-supported digital twins.
Engineering context first
We start by understanding your needs, then design the infrastructure and adapt our software to meet your project’s requirements.
Traceable by design
Source context, run state, and release metadata stay visible so teams can review how an engineering result was produced.
Grounded in real environment
Our solutions are developed and tested in real-world environments, where changing conditions and complex traffic scenarios put them to the test.
Meet the founders
5 founders are presented across DriveByCloud’s published executive and technical roles.
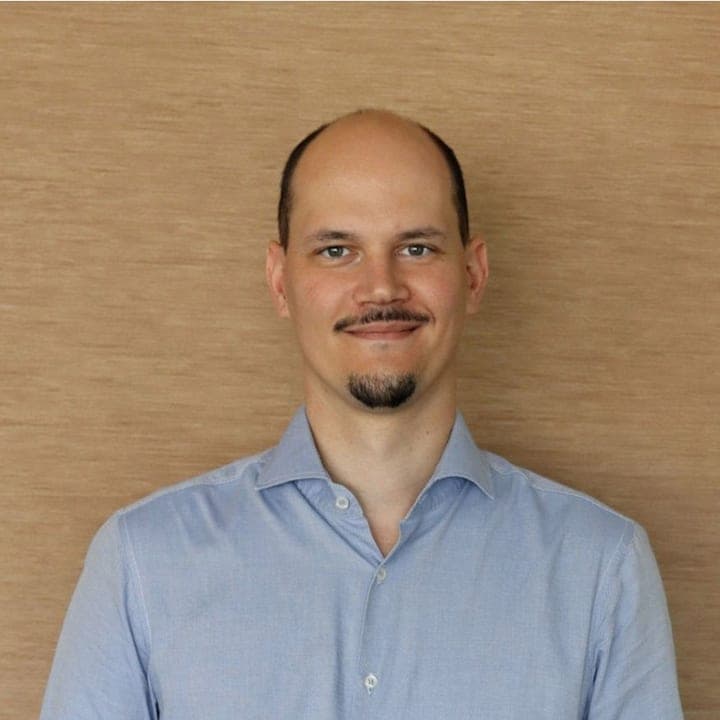
Zsolt Vincze
CEO & Co-founder
- Multi-sensor architecture design
- Reference-data system deployment
- Certified ISO 9001 auditor
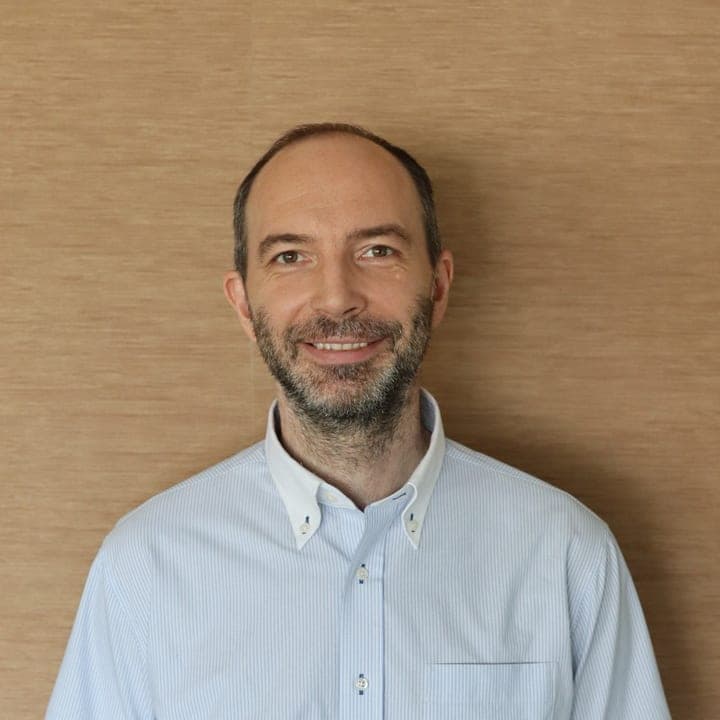
András Rövid, PhD
CTO & Co-founder
- Camera–LiDAR raw sensor fusion
- Computer vision and 3D object detection
- Senior research fellow, BME automotive technologies
Zsolt Szalay, PhD
Executive Advisor & Co-founder
- Verification and validation of automated vehicles
- ZalaZONE proving-ground concept and R&D
- Founder of the BME Automated Drive Laboratory
Viktor Tihanyi, PhD
Executive Advisor & Co-founder
- Automated-driving research programme management
- Autonomous test vehicles and perception platforms
- Mechatronics, co-inventor of 14 patents
Viktor Remeli
Executive Advisor & Co-founder
- Verification of deep neural networks
- DNN-based raw sensor fusion
- AI research for automotive applications
Our publications
Our publications showcase the expertise we have built through research and real-world projects.
| Year | Publication | Venue | Link |
|---|---|---|---|
| 2026 | Aerial Imagery-Based Validation of an Infrastructure-Based Highway Traffic Perception System Zsombor Páncsics, Máté Fugerth, Bálint Patkó, Csaba Marosi, Gergely Treplán, Márton Cserni, Mihály Csonthó, Zsolt Vincze, András Rövid, Levente Hajder, Imre Benedek Juhász | IEEE Access 14, 156609–156624 | DOI10.1109/ACCESS.2026.3739894 (opens in a new tab) |
| 2026 | Ground-Vehicle-Assisted Monocular vSLAM Correction for UAV Pose Estimation Károly Fodor, Márton Cserni, András Rövid | IEEE Access (early access) | DOI10.1109/ACCESS.2026.3739020 (opens in a new tab) |
| 2026 | Kooperatív vizuális SLAM rendszer járműalapú környezetérzékelésre (Cooperative visual SLAM for vehicle-based environment perception) Károly Fodor, András Rövid | Közlekedéstudományi Szemle 76(3), 28–35 | DOI10.24228/KTSZ.2026.3.4 (opens in a new tab) |
| 2026 | On the Classification of Vehicle Cut-In Scenarios Severity: Empirical Evidence to Validate the Severity Classification of UN R157 Sandor Vass, Konstantinos Mattas, Riccardo Donà, Marton Pataki, Biagio Ciuffo, Maria Cristina Galassi, Zsolt Szalay, Viktor Tihanyi | IET Intelligent Transport Systems 20(1), e70157 | DOI10.1049/itr2.70157 (opens in a new tab) |
| 2025 | Reference Platform for ADAS Camera System Evaluation András Rövid, Zsolt Vincze, Tamás Pálinkás, Mihály Kocsis, Viktor Serrano, Zsolt Szalay | Sensors 25(6), 1690 | DOI10.3390/s25061690 (opens in a new tab) |
| 2025 | MM-VSM: Multi-Modal Vehicle Semantic Mesh and Trajectory Reconstruction for Image-Based Cooperative Perception Márton Cserni, András Rövid, Zsolt Szalay | Applied Sciences 15(12), 6930 | DOI10.3390/app15126930 (opens in a new tab) |
| 2025 | GS-ReLoc: A Gaussian-Splatting Relocalization Method for Robust and Accurate Mono Camera Pose Estimation Károly Fodor, András Rövid | IEEE Access 13, 107080–107092 | DOI10.1109/ACCESS.2025.3581068 (opens in a new tab) |
| 2025 | Pillar-X: Integrating Self-Learned Image Features to Improve 3D Object Detection Mihály Csonthó, András Rövid | IEEE Access 13, 83071–83081 | DOI10.1109/ACCESS.2025.3567658 (opens in a new tab) |
| 2025 | Aggregated Time Series Features in a Voxel-Based Network Architecture Zsolt Vincze, András Rövid | IEEE Access 13, 19329–19339 | DOI10.1109/ACCESS.2025.3535151 (opens in a new tab) |
| 2025 | Enhancing NetVLAD Based Localization with Gaussian Splat Károly Fodor, András Rövid | IEEE SAMI 2025, 359–364 | DOI10.1109/SAMI63904.2025.10883320 (opens in a new tab) |
| 2025 | TACO: Adversarial Camouflage Optimization on Trucks to Fool Object Detectors Adonisz Dimitriu, Tamás Vilmos Michaletzky, Viktor Remeli | Big Data and Cognitive Computing 9(3), 72 | DOI10.3390/bdcc9030072 (opens in a new tab) |
| 2024 | Digital Twin and Cloud Based Remote Control of Vehicles András Rövid, Viktor Tihanyi, Márton Cserni, Mihály Csonthó, Ádám Domina, Viktor Remeli, Zsolt Vincze, Mátyás Szántó, Mátyás Szalai, Szabolcs Nagy, Zsolt Szalay | IEEE MOST 2024, 154–167 | DOI10.1109/MOST60774.2024.00024 (opens in a new tab) |
| 2024 | Semantic Shape and Trajectory Reconstruction for Monocular Cooperative 3D Object Detection Márton Cserni, András Rövid | IEEE Access 12, 167153–167167 | DOI10.1109/ACCESS.2024.3484672 (opens in a new tab) |
| 2024 | Benyúló karos tartószerkezet alkalmazási lehetőségének vizsgálata a ZalaZONE tesztpályán kialakítandó percepciós szenzorrendszer vonatkozásában (Cantilever gantry options for a perception sensor system at ZalaZONE) Márton Cserni, Zsolt Vincze, András Rövid, Mihály Csonthó, Ádám Boronyák, Lóránt Kovács | Közlekedéstudományi Szemle 74(6), 15–24 | DOI10.24228/KTSZ.2024.6.2 (opens in a new tab) |
| 2024 | Mapping Lane Markings with Multi-Sensor Data Mihály Csonthó, András Rövid | IEEE SAMI 2024, 47–52 | DOI10.1109/SAMI60510.2024.10432824 (opens in a new tab) |
| 2023 | Critical Scenario Identification Concept: The Role of the Scenario-in-the-Loop Approach in Future Automotive Testing Zsolt Szalay | IEEE Access 11, 82464–82476 | DOI10.1109/ACCESS.2023.3298875 (opens in a new tab) |
| 2023 | Model Predictive Controller Approach for Automated Vehicle’s Path Tracking Ádám Domina, Viktor Tihanyi | Sensors 23(15), 6862 | DOI10.3390/s23156862 (opens in a new tab) |
| 2022 | Automatic Label Injection Into Local Infrastructure LiDAR Point Cloud for Training Data Set Generation Zsolt Vincze, András Rövid, Viktor Tihanyi | IEEE Access 10, 91213–91226 | DOI10.1109/ACCESS.2022.3202223 (opens in a new tab) |
| 2022 | Significance of Image Features in Camera-LiDAR Based Object Detection Mihály Csonthó, András Rövid, Zsolt Szalay | IEEE Access 10, 61034–61045 | DOI10.1109/ACCESS.2022.3181137 (opens in a new tab) |
| 2022 | 3D Object Detection in LIDAR Point Cloud Based on Background Subtraction Szabolcs Nagy, András Rövid | BME ZalaZONE R&I Conference 2022, 20–23 | DOI10.3311/BMEZalaZONE2022-004 (opens in a new tab) |
| 2022 | Teleoperation with a Real-time Digital Twin Viktor Remeli, Ádám Boronyák, Viktor Tihanyi | BME ZalaZONE R&I Conference 2022, 34–38 | DOI10.3311/BMEZalaZONE2022-007 (opens in a new tab) |
| 2021 | Towards Cooperative Perception Services for ITS: Digital Twin in the Automotive Edge Cloud Viktor Tihanyi, András Rövid, Viktor Remeli, Zsolt Vincze, Mihály Csonthó, Zsombor Pethő, Mátyás Szalai, Balázs Varga, Aws Khalil, Zsolt Szalay | Energies 14(18), 5930 | DOI10.3390/en14185930 (opens in a new tab) |
| 2021 | Motorway Measurement Campaign to Support R&D Activities in the Field of Automated Driving Technologies Viktor Tihanyi, Tamás Tettamanti, Mihály Csonthó, …, Viktor Remeli, András Rövid, …, Zsolt Vincze, …, Zsolt Szalay | Sensors 21(6), 2169 | DOI10.3390/s21062169 (opens in a new tab) |
| 2020 | Raw fusion of camera and sparse LiDAR for detecting distant objects András Rövid, Viktor Remeli, Zsolt Szalay | at – Automatisierungstechnik 68(5), 337–346 | DOI10.1515/auto-2019-0086 (opens in a new tab) |
| 2020 | Towards Reliable Multisensory Perception and Its Automotive Applications András Rövid, Viktor Remeli, Norbert Paufler, Henrietta Lengyel, Máté Zöldy, Zsolt Szalay | Periodica Polytechnica Transportation Engineering 48(4), 334–340 | DOI10.3311/PPtr.15921 (opens in a new tab) |
| 2019 | Towards Verifiable Specifications for Neural Networks in Autonomous Driving Viktor Remeli, Sunil Morapitiye, András Rövid, Zsolt Szalay | IEEE CINTI-MACRo 2019, 175–180 | DOI10.1109/CINTI-MACRo49179.2019.9105190 (opens in a new tab) |
| 2019 | Towards Raw Sensor Fusion in 3D Object Detection András Rövid, Viktor Remeli | IEEE SAMI 2019, 293–298 | DOI10.1109/SAMI.2019.8782779 (opens in a new tab) |
| 2018 | Development of a Test Track for Driverless Cars: Vehicle Design, Track Configuration, and Liability Considerations Zsolt Szalay, Tamás Tettamanti, Domokos Esztergár-Kiss, István Varga, Cesare Bartolini | Periodica Polytechnica Transportation Engineering 46(1), 29–35 | DOI10.3311/PPtr.10753 (opens in a new tab) |
Quality management
A TÜV Rheinland certificate records that DriveByCloud Kft met the requirements of ISO 9001:2015 for its listed scope at the time of audit.
ISO 9001:2015
A TÜV Rheinland certificate records that DriveByCloud Kft met the requirements of ISO 9001:2015 for its listed scope at the time of audit.
- Registration
- 01 100 2324073
- Published validity
- –
- Listed scope
- Data process and webhosting; scientific and technical research and development.
The published certificate states validity from 18 October 2023 to 17 October 2026. Confirm renewal status before describing it as current after that date.
Start with your environment and engineering question
We will help map your sources, test process, and review needs to the appropriate DriveByCloud product.